Made in America
Get Connected With


Choosing the best Industrial Gripper from China requires more than comparing prices or catalogue images. The decision affects cycle time, product damage, maintenance, and operator safety. China’s manufacturing scale creates many capable suppliers, yet quality remains uneven. That matters.
The International Federation of Robotics reported 541,302 industrial robots were installed worldwide in 2023. Each installation needs reliable end-of-arm tooling. MarketsandMarkets also identifies growing demand for robotic grippers, driven by automation, collaborative robots, and flexible production. These reports show a clear trend. Grippers are becoming strategic production components, not simple accessories.
As Dr. Markus Glück, a well-known SCHUNK automation expert, has stated, “The gripper is the handshake between the robot and the workpiece.” That principle helps frame this comparison. The best Chinese gripper must match the material, payload, stroke, gripping force, environment, and robot interface. It should also provide repeatable performance after thousands of cycles.
Look closely.
A low purchase price can hide expensive downtime. A pneumatic model may suit fast packaging, while an electric gripper may offer better force control for delicate electronics. IP ratings, spare-part access, response time, and technical support deserve equal attention. Certification and documented testing also strengthen supplier credibility.
This guide will compare Chinese Industrial Gripper manufacturers through practical criteria, including engineering experience, product reliability, customization, after-sales support, and verified application results. No supplier wins every test. That is the uncomfortable part. The right choice depends on evidence from your process, not marketing language alone.
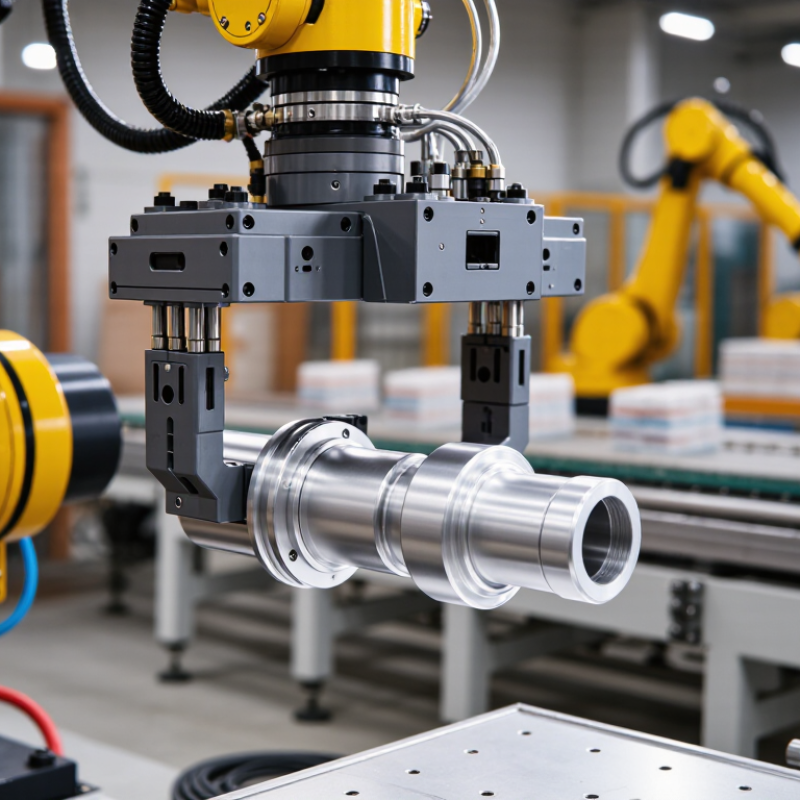
The best industrial gripper is not judged by appearance or the lowest quotation. It must match the robot, workpiece, cycle time, and production environment. During line trials, engineers should measure gripping force, opening speed, repeatability, and air consumption under real conditions. A polished demonstration can hide problems.
Jaw materials should protect surfaces without slipping. Finger geometry must fit actual parts, including burrs, oil, and dimensional variation. Payload ratings need practical safety margins, not optimistic laboratory figures. In dusty workshops, sealed guides and accessible lubrication points can prevent frequent stoppages. Electrical and pneumatic interfaces should follow recognized industrial standards.
I once saw a gripper pass a short test, then lose accuracy after continuous cycling. The cause was not dramatic; its guide system warmed and developed slight play. That experience changed my inspection habits. I now request endurance data, maintenance intervals, spare-part availability, and traceable test records. Reliability depends on evidence.
Clear documentation also defines quality. Suppliers should provide force curves, installation limits, tolerance information, and inspection reports. Ask how each figure was measured. Ask again when answers seem vague. Packaging deserves attention too, because corrosion protection and alignment fixtures can affect the first installation. Some buyers overlook this. Not glamorous, but costly failures often begin there.
Choosing the best industrial gripper from China starts with the workpiece, not the catalog. The IFR World Robotics 2024 report recorded 541,302 industrial robot installations worldwide in 2023. China represented 276,288 installations, or 51 percent of the global total. This scale supports broad engineering capacity, but capacity does not guarantee a suitable gripper. Selection should consider weight, surface, temperature, cycle time, and allowable contact marks. Ask for measured data, not only brochure claims.
Parallel two-finger grippers suit rigid blocks, shafts, and repeatable machine tending. They are simple, fast, and usually easy to maintain. Angular grippers help when jaw clearance is limited around the part. Three-finger models center round components more reliably than many two-finger designs. Vacuum grippers fit cartons, glass, films, and smooth panels with large contact areas. Porous surfaces need foam pads or multiple vacuum circuits. Magnetic grippers handle ferrous sheets, although oil, burrs, and double-sheet pickup require testing.
MarketsandMarkets’ Industrial Robotics Market analysis projects strong growth through 2028, increasing pressure to automate flexible production lines. That pressure can make a low-cost purchase look attractive. It can also hide integration costs. Check jaw stroke, gripping force at actual pressure, sensor feedback, IP rating, spare-part lead time, and applicable safety documentation. In practical trials, a gripper passing ten dry cycles may fail after dust, oil, or heat appears. That is the uncomfortable part. Request sample testing, repeatability records, and clear failure limits before ordering. The best option is the one whose tested behavior matches your production line, not its advertised maximum.
| Gripper Type | Typical Gripping Principle | Best-Suited Applications | Suitable Workpiece Characteristics | Main Advantages | Key Limitations | Common Automation Compatibility | Recommended Selection Priorities |
|---|---|---|---|---|---|---|---|
| Two-Finger Parallel Gripper | Two jaws move linearly toward or away from the workpiece and hold it by external or internal contact. | Machine tending, assembly, pick-and-place, packaging, and part transfer. | Rigid, regularly shaped parts with accessible gripping surfaces, including machined components, housings, and fixtures. | Simple design, repeatable positioning, broad jaw and finger options, and easy integration with robot tooling. | Less suitable for irregular, fragile, highly slippery, or very thin parts unless custom fingers are used. | Six-axis robots, SCARA robots, Cartesian systems, and collaborative robots. | Jaw stroke, gripping force, repeatability, finger length, payload, and protection against part rotation. |
| Two-Finger Angular Gripper | Jaws pivot around a hinge and open or close through an angular motion. | Basic handling, low-cost pick-and-place, packaging, and applications with limited jaw travel requirements. | Rigid parts that can be accessed from above or from the side and do not require a long parallel stroke. | Compact construction, relatively low weight, and convenient operation in restricted spaces. | Jaw motion changes the contact point during closing, which can reduce positioning accuracy for some parts. | Small robotic cells, pneumatic automation, and general-purpose handling systems. | Opening angle, available mounting space, closing force, part geometry, and repeatability. |
| Three-Finger Centric Gripper | Three fingers move toward a common center to create a balanced radial grip. | Turning-lathe loading, cylindrical-part handling, concentric assembly, and inspection operations. | Round, hexagonal, or approximately symmetrical components such as shafts, rings, tubes, and fittings. | Good centering capability, balanced gripping, and improved stability for cylindrical workpieces. | Usually less effective for flat, asymmetrical, or highly irregular parts; access can be more demanding. | CNC machine tending, rotary indexing systems, and industrial robot applications. | Centering accuracy, gripping diameter range, radial force, jaw stroke, and chip or coolant resistance. |
| Vacuum Gripper | Vacuum pressure creates a differential force between a suction cup and the workpiece surface. | Sheet handling, carton handling, glass transfer, packaging, palletizing, and smooth-surface pick-and-place. | Clean, relatively smooth, non-porous surfaces with sufficient contact area and suitable load orientation. | Fast handling, no mechanical jaw marks, ability to cover large surfaces, and suitability for thin sheets. | Performance decreases on porous, dusty, rough, oily, or heavily textured surfaces; vacuum loss can cause dropped parts. | Industrial robots, gantry systems, palletizing cells, and high-speed packaging machines. | Suction-cup material and diameter, vacuum level, leakage rate, safety reserve, surface condition, and filtration. |
| Magnetic Gripper | Permanent magnets or controllable electromagnets attract ferromagnetic workpieces. | Steel sheet handling, stamped-part transfer, metal loading, and movement of ferrous components. | Ferromagnetic materials with an adequately flat or accessible contact area. | Fast engagement, effective handling of steel parts, and good performance where mechanical access is limited. | Not suitable for aluminum, copper, plastics, or most stainless steels; residual magnetism and contamination may be concerns. | Press lines, material-transfer systems, robots, and automated storage or loading equipment. | Material type, air gap, surface contamination, load orientation, release behavior, and fail-safe requirements. |
| Soft or Adaptive Gripper | Compliant fingers deform around the workpiece using elastomeric, flexible, pneumatic, or tendon-driven structures. | Food handling, consumer-product packaging, laboratory automation, and mixed-part handling. | Fragile, irregular, delicate, or variable-shaped items that benefit from gentle and conforming contact. | Low contact stress, adaptable gripping, reduced part damage, and reduced need for complex custom fingers. | Lower stiffness and precision than rigid grippers in some applications; wear and cleaning requirements vary by design. | Collaborative robots, light-duty industrial robots, and flexible production cells. | Payload, compliance, hygiene requirements, gripping speed, material durability, and repeatability. |
| Internal Expanding Gripper | Expandable fingers or elements move outward inside a bore or cavity to create an internal grip. | Ring handling, tube handling, machining operations, and transfer of parts with accessible internal diameters. | Parts with a sufficiently strong and consistent internal hole, bore, or cavity. | Leaves exterior surfaces accessible, supports stable transfer, and can reduce interference with external features. | Requires a suitable internal feature; excessive expansion force may deform thin-walled components. | CNC machine tending, assembly equipment, and robotic transfer systems. | Expandable diameter, internal surface condition, radial force, insertion depth, and part-wall strength. |
| Long-Stroke Gripper | Extended jaw travel allows the gripper to handle a comparatively wide range of part sizes. | Mixed-size component handling, pallet transfer, bin picking, and operations requiring wide jaw adjustment. | Parts with significantly different dimensions but reasonably consistent gripping surfaces. | Wide operating range, fewer tool changes, and greater flexibility for varied production batches. | Longer stroke can increase size, mass, closing time, and potential jaw deflection. | Industrial robots, collaborative robots, and flexible manufacturing systems. | Total stroke, gripping force across the stroke, weight, cycle time, rigidity, and sensor feedback. |
| Needle Gripper | Thin needles penetrate or engage a porous or fibrous workpiece to create a mechanical hold. | Textiles, insulation, foam, cardboard, and other porous materials that are difficult to grip with suction. | Soft, fibrous, porous, or compressible materials that tolerate controlled needle penetration. | Can handle porous materials without depending on an airtight surface and can work with irregular shapes. | May leave marks, damage delicate products, or create safety and maintenance concerns if needles are exposed. | Specialized handling machines, packaging equipment, and selected robotic applications. | Needle length, penetration force, material damage tolerance, guarding, maintenance, and cleaning access. |
Selecting the best industrial gripper from China requires more than comparing prices. Quality begins with measurable force, repeatability, and material control. Ask for test records, not polished photographs. ISO 9283 defines methods for evaluating robot accuracy and repeatability, which helps standardize supplier comparisons. For a gripper, check positioning repeatability under the real payload, not an unloaded bench test. Measure jaw movement with a calibrated gauge. Small errors become serious when parts are thin, oily, or flexible.
Durability needs evidence from operating conditions. Request cycle-test results, seal ratings, corrosion checks, and replacement-part availability. A useful trial should reproduce the factory: dust, vibration, temperature changes, and continuous opening and closing. The International Federation of Robotics reported 541,302 industrial robot installations worldwide in 2023, in World Robotics 2024. That scale increases pressure on grippers to deliver stable uptime, not impressive short-term speed. The same report recorded global robot density at 162 units per 10,000 manufacturing employees in 2023, showing how tightly automation is entering production.
Precision is also a system issue. Air pressure variation, mounting flex, and poor finger design can distort results. I would test at least three batches of parts, with several operators and repeated shifts. Perfect samples can mislead. A gripper that passes a laboratory test may fail beside a machining line after two months. Record force loss, cycle time, jaw wear, and rejected parts. Then compare the results with the supplier’s stated limits, leaving room for uncertainty and maintenance.
What Is the Best Industrial Gripper from China?
The best industrial gripper is rarely the cheapest quotation. Buyers should compare total ownership cost, not only the purchase price. Include tooling, installation, air consumption, electrical control, spare fingers, and downtime. The International Federation of Robotics reported 541,302 industrial robots were installed worldwide in 2023. That scale increases demand for reliable end-of-arm tooling and responsive service. In my experience, a low-cost gripper can become expensive when replacement seals arrive late. Performance also depends on payload, cycle time, grip force, repeatability, and the workpiece surface. Ask suppliers for test videos using your actual parts.
Tips: Request a five-year cost model. Measure air use per cycle. Check replacement-part lead times. Require a written acceptance test.
Compliance deserves equal attention. Confirm whether the gripper supports the robot cell’s risk assessment and guarding design. ISO 10218 covers industrial robot safety, while ISO/TS 15066 provides guidance for collaborative applications. These documents do not automatically certify a complete machine. The integrator still must validate the finished cell. Check material certificates, electrical drawings, ingress protection, and functional safety interfaces. A supplier should provide traceable inspection records and clear manuals in your working language. Service quality is harder to measure. Set response times, remote diagnosis procedures, training hours, and escalation contacts in the contract. Good support feels invisible until production stops. That is the uncomfortable test. A factory visit, sample trial, and documented failure analysis may reveal more than polished specifications. IFR data shows strong global automation demand, but demand alone does not prove every model fits your process. Test carefully.
What Is the Best Industrial Gripper from China?
Choosing the right Chinese gripper starts with the workpiece, not the catalog. Measure its weight, surface texture, temperature, and gripping area. Calculate the required force with a safety margin, especially when the robot accelerates or rotates. A gripper that works on a test bench may slip during a fast production cycle. The first selection may be wrong. That is acceptable if testing begins early.
Tips: Request a detailed datasheet, force curves, stroke limits, cycle-life data, and material information. Test the gripper with real parts, oil, dust, and temperature changes. Check finger deflection, sensor repeatability, mounting dimensions, and replacement-part availability. Ask for sample inspection records and a clear acceptance procedure. Do not rely only on attractive price or polished videos.
Integration requires more than attaching a flange. Confirm the robot payload, mounting pattern, electrical voltage, pneumatic pressure, and controller communication. Plan cable routing and include strain relief near moving joints. Verify open and close signals, fault feedback, emergency-stop behavior, and recovery after power loss. For electric models, inspect software compatibility and adjustable force settings. For pneumatic models, check air quality and response time. A small pressure drop can change gripping performance. Local technical support can reduce delays, but response promises should be written into the supply agreement. Keep a trial report, record failures honestly, and revise the selection when real production exposes weak assumptions.